Harry Haoyang Li
Hi there! I'm a roboticist and researcher engineer at UC San Diego. I'm grateful to collaborate with Prof. Leonidas J. Guibas. I was previously advised by Prof. Hao Su.
Build
I help teams developing frontier world models bring them into robotics, from infrastructure to action policies. I care about turning research into working systems.
Research
I study how robots and multimodal agents understand, simulate, learn from, and act in the physical world. I want to help build general physical intelligence and an AI-driven physical economy.
I am on the job market; shoot me an email if there is a good fit.
Cosmos 3 Edge Policy
NVIDIA Cosmos Team
NVIDIA Cosmos, 2026
TL;DR Brings world models to on-device robot control, jointly predicting manipulation actions and future video from language instructions and visual inputs.
Webpage •
Code •
Model
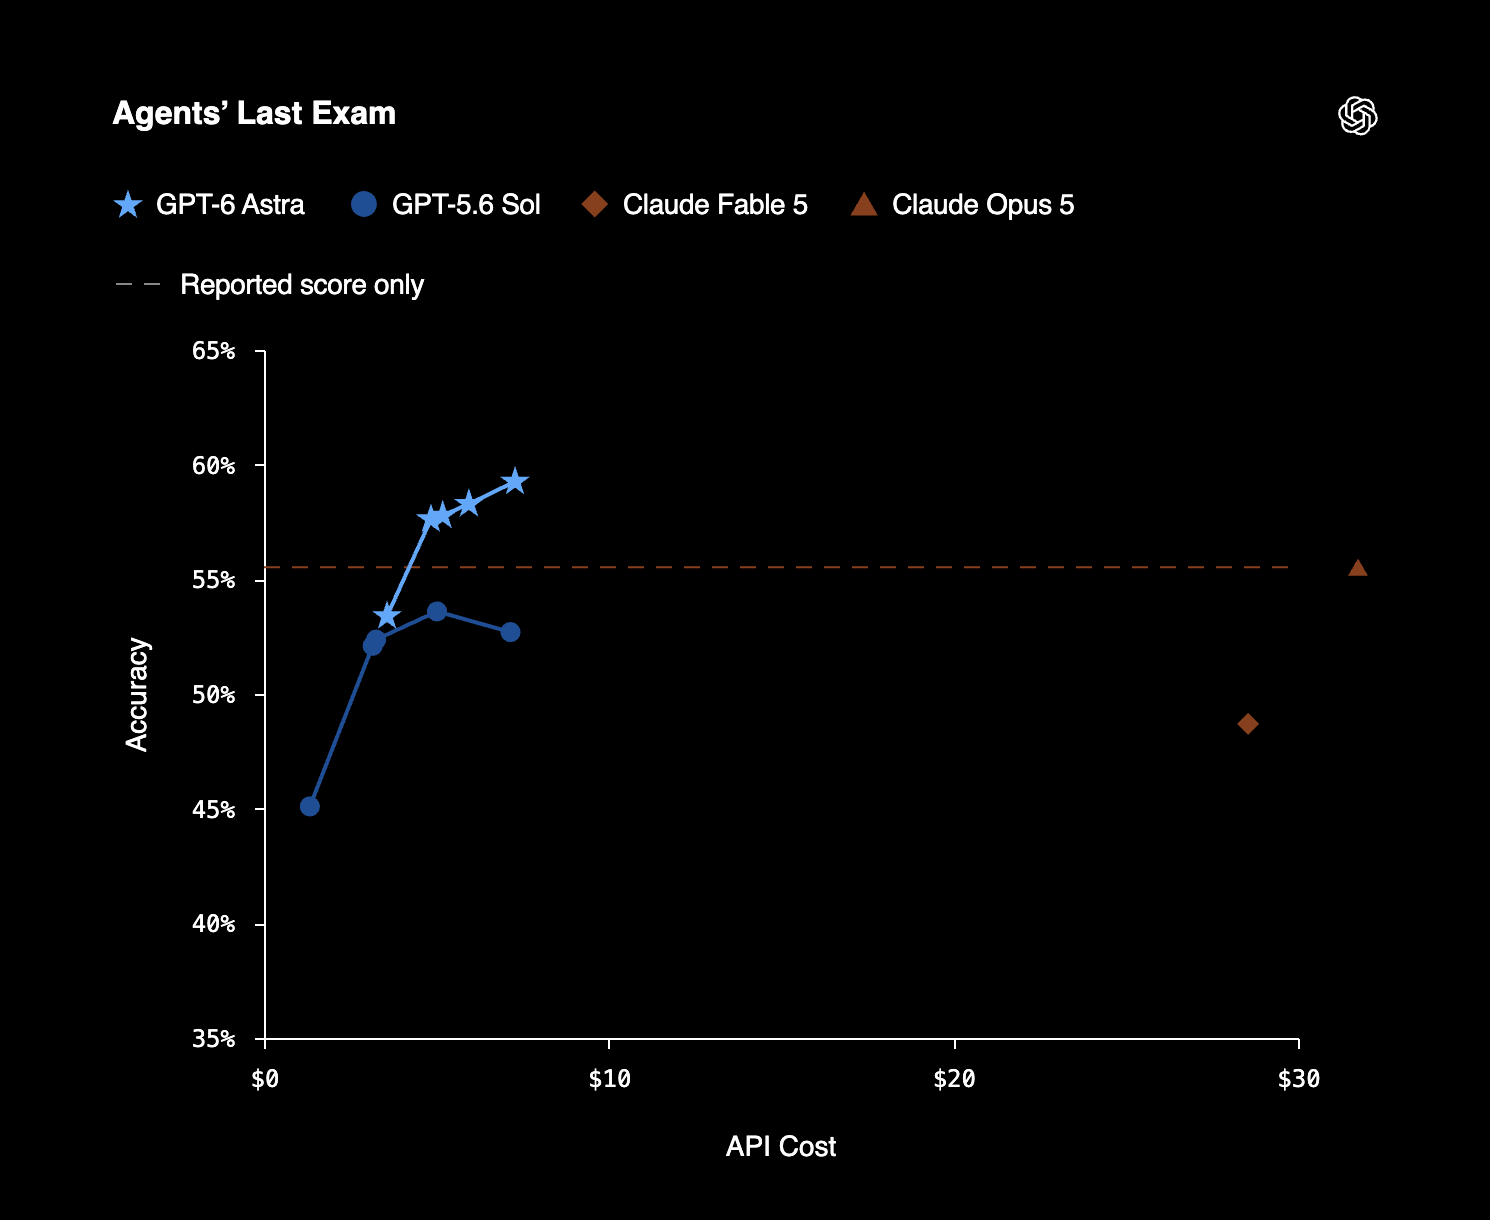
Agents' Last Exam
Agents' Last Exam Collaboration (Haoyang Li; 310 authors)
arXiv, 2026
Used in GPT-6 Astra and Gemini 4 Argon evaluations
TL;DR Tests AI agents on long-horizon professional workflows with verifiable outcomes across 55 subdomains and 13 industry clusters.
Webpage •
PDF •
Code •
OpenAI •
Google
PhysMem: Scaling Test-Time Memory for Embodied Physical Reasoning
Haoyang Li, Yang You, Hao Su, Leonidas Guibas
arXiv, 2026
Oral @ CVPR 2026 Workshop on Interactive Physical AI (IPA)
ICLR 2026 Workshop on Lifelong Agents: Learning, Aligning, Evolving
TL;DR Learns and verifies physical principles from interaction at test time, using persistent memory to guide robot planning without updating model weights.
Webpage •
PDF •
Code •
Thread
Diffusion Dynamics Models with Generative State Estimation for Cloth Manipulation
Tongxuan Tian*, Haoyang Li*, Bo Ai, show more
Conference on Robot Learning (CoRL), 2025
Oral @ CoRL 2025 Workshop on Learning to Simulate Robot Worlds
TL;DR Combines diffusion dynamics and generative state estimation for cloth manipulation, reducing long-horizon prediction error 10× versus GNNs.
Webpage •
PDF •
Code
Hillbot Alpha: A Sim-to-Real Breakthrough in Mobile Manipulation Robotics
Hillbot Team
Hillbot Alpha Demo, 2024
Featured in NVIDIA's CES 2025 showcase
TL;DR Brings simulation-trained policies to a mobile manipulation robot, demonstrating sim-to-real transfer and real-world robot operation.
Video
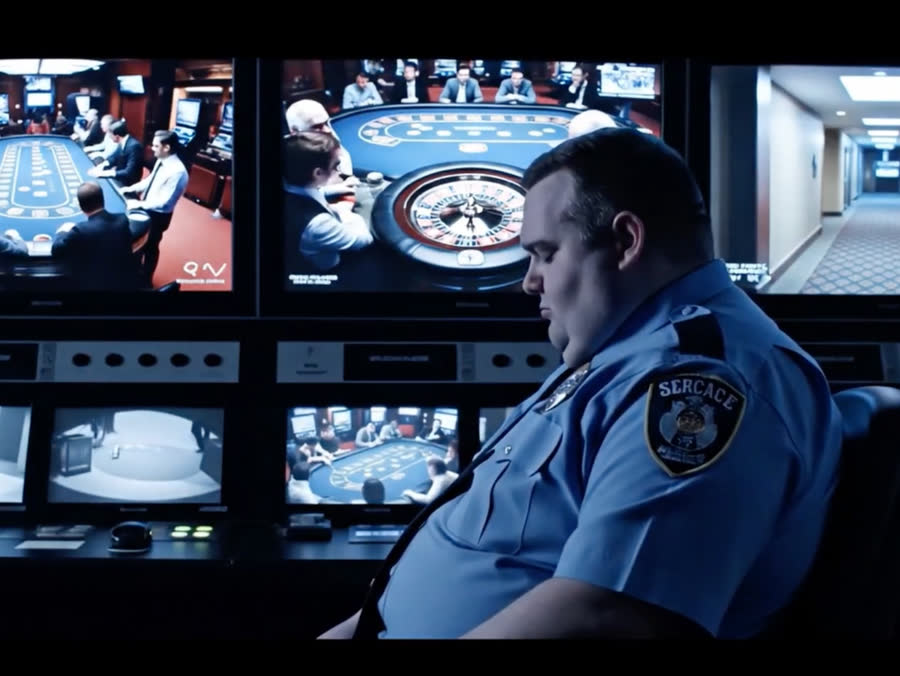
Security Multimodal Agent (AEGIS)
2025
Google ADK Hackathon
A multimodal security agent combining language models and real-time vision to turn passive surveillance into interactive monitoring and response.
Related: CCTV Agent
Code •
Video
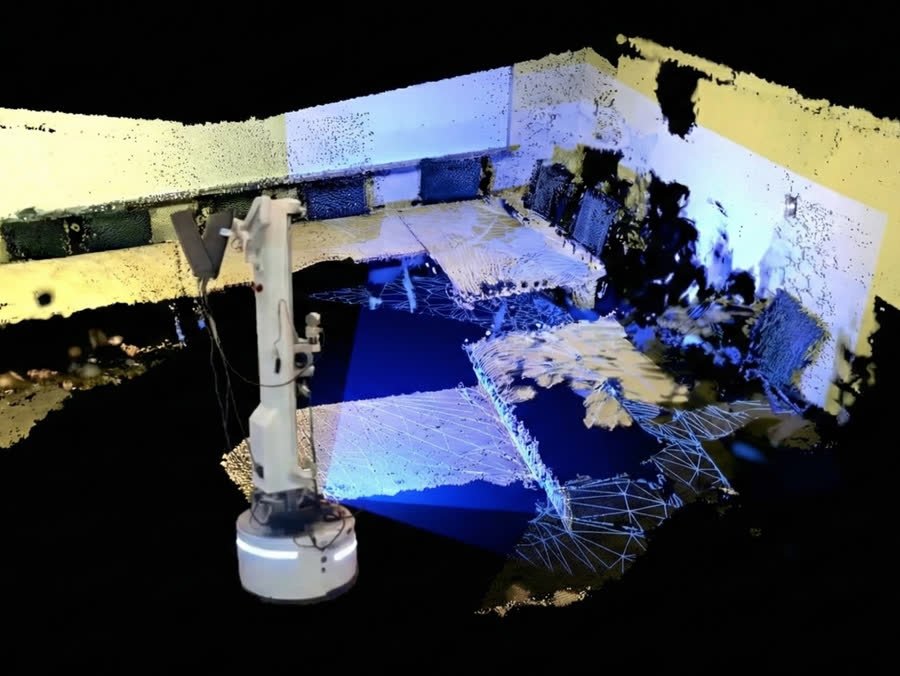
3DGS Active Exploration Agent
2024
Autonomously explores unknown indoor environments with LiDAR and RGB-D, reconstructing detailed 3D scenes with Gaussian splatting.
Related: World Labs · 3D generation
Code
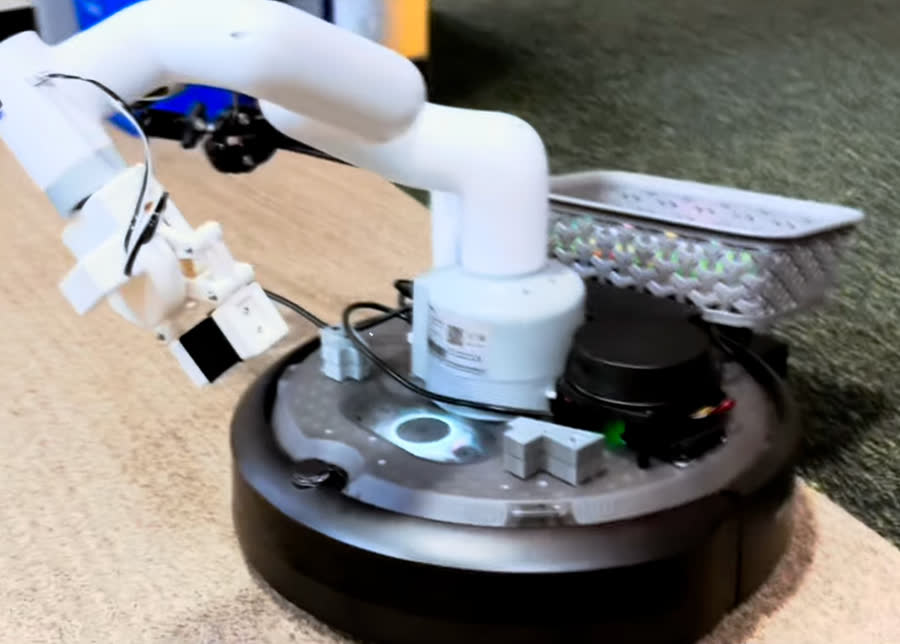
Home Cleaning Mobile Manipulation
2024
A mobile manipulation platform combining a collaborative arm and mobile base for household tasks, including picking up and tidying toys.
Related: Roborock Saros Z70
Video
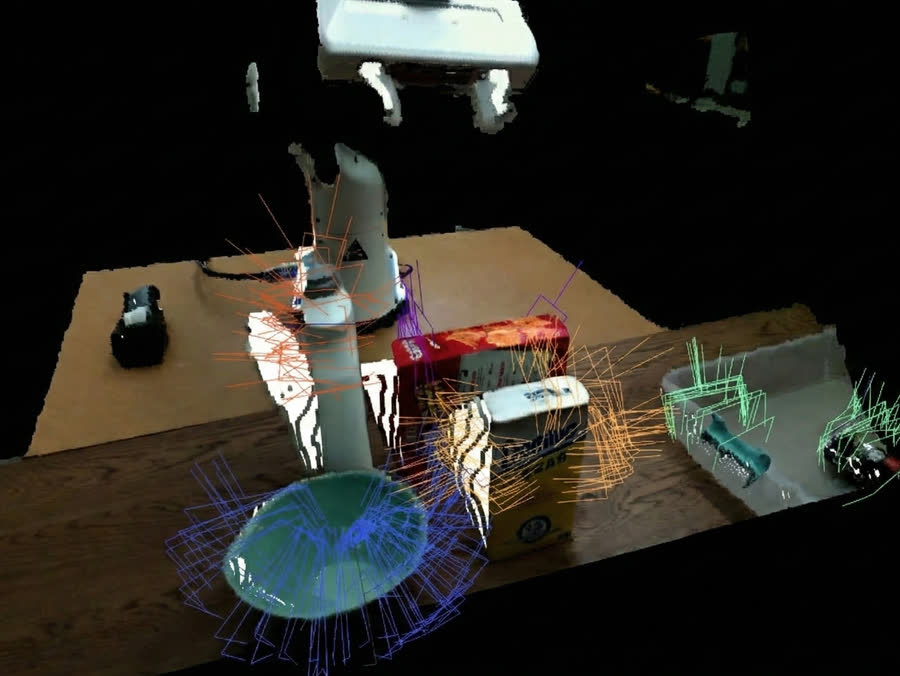
Antipodal Grasp Generation
2023
Analyzes 3D object meshes to generate collision-free antipodal grasps for a Franka robot, supporting reinforcement learning priors and hardware co-design.
Code
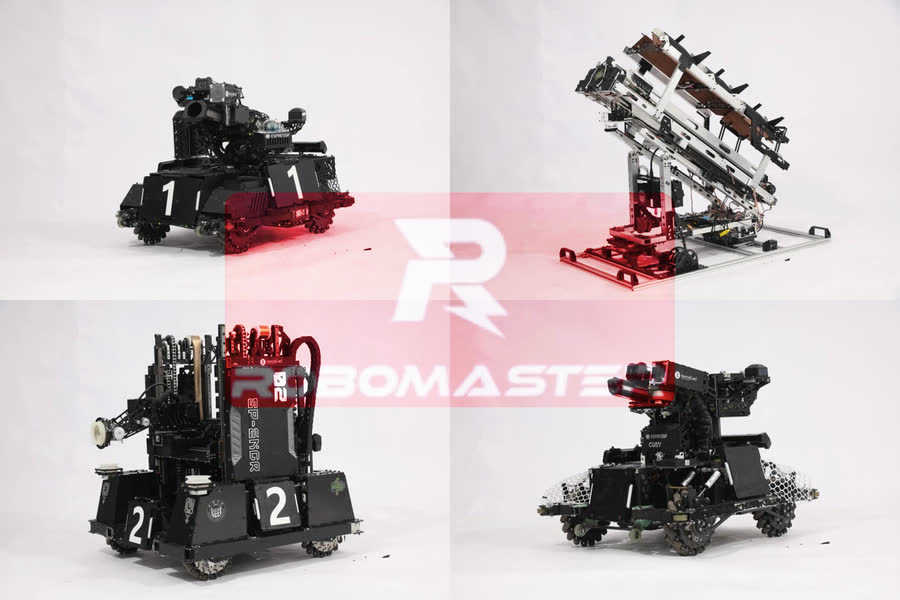
RoboMaster
2020
Led mechanical design of the dart launcher system for the RoboMaster University Series global competition.
To see the spectrum, to voice the silence.